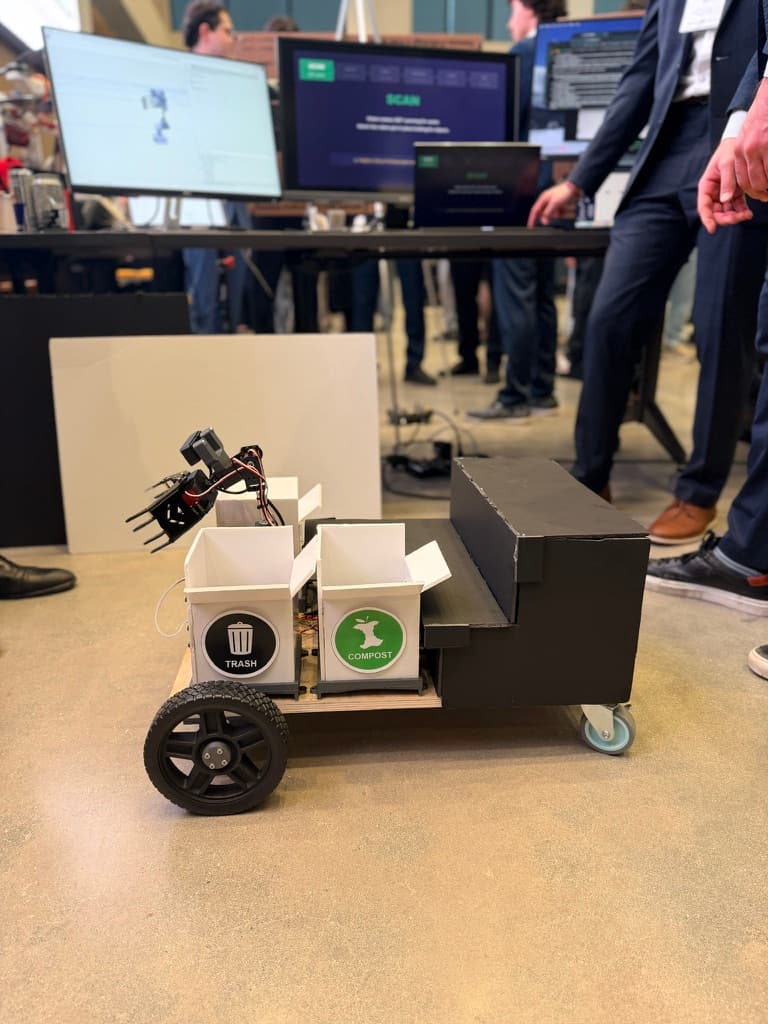
SHT 01Robotics · ROS2 · Computer Vision
I build autonomous robots, applied machine learning and AI systems, and full-stack tools.
Everything here is something I designed, built, and shipped.
Six projects, five I designed and built, one I fought for.
Two autonomous robots, an offline reinforcement-learning agent, two clinical machine-learning tools, and a federal advocacy campaign.
Open any sheet for the full story.
SHT 01Robotics · ROS2 · Computer Vision

SHT 02Robotics · ROS2 · Nav2 · Computer Vision
SHT 03Clinical machine learning · Published

SHT 04Reinforcement learning
SHT 05Clinical machine learning
Grounded: what it’s like to be a No Fly List kid
SHT 06Advocacy · Policy
The work I care about sits where hardware and software meet.
It isn't finished until someone who isn't an engineer can understand it.
A few habits I keep coming back to.
01
My best work is where separate parts become one system. On RECLAIM that meant perception, control, firmware, and the arm. On the wheelchair it meant a vendor ROS2 stack running alongside my own nodes. Mechatronics taught me to work across the seams, not stay in one lane.
RECLAIM · the full stack02
I was the only engineer among the MDs and PhDs on a published clinical paper, and at 16 I wrote a Toronto Star op-ed and did national interviews about a security-list failure. I can make a system legible to the people who have to act on it.
THA · the only engineer in the room03
A startup taught me the job is whatever moves it forward, whether that's a pitch deck, a live demo, a cold-outreach email, or grunt work. I find what needs doing and start on it, instead of waiting for the work to arrive already scoped.
No Fly List Kids · eight years of it04
I'd rather ship a result you can poke at than a number you have to trust. So I audit my own work until it holds, and where I can, I put it in front of people so they can check it too.
NBA · the live explorerOpen to roles and collaborations in robotics, AI and machine learning, and full-stack engineering.